robo-evals
Seeded, reproducible success rates for robot manipulation policies in MuJoCo, with confidence intervals and episode videos.
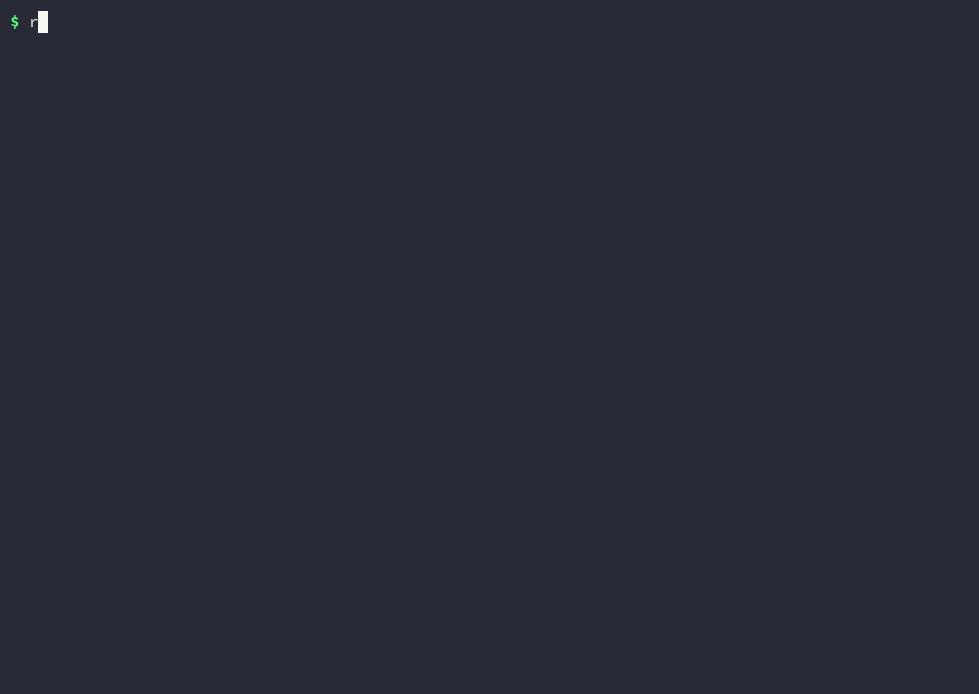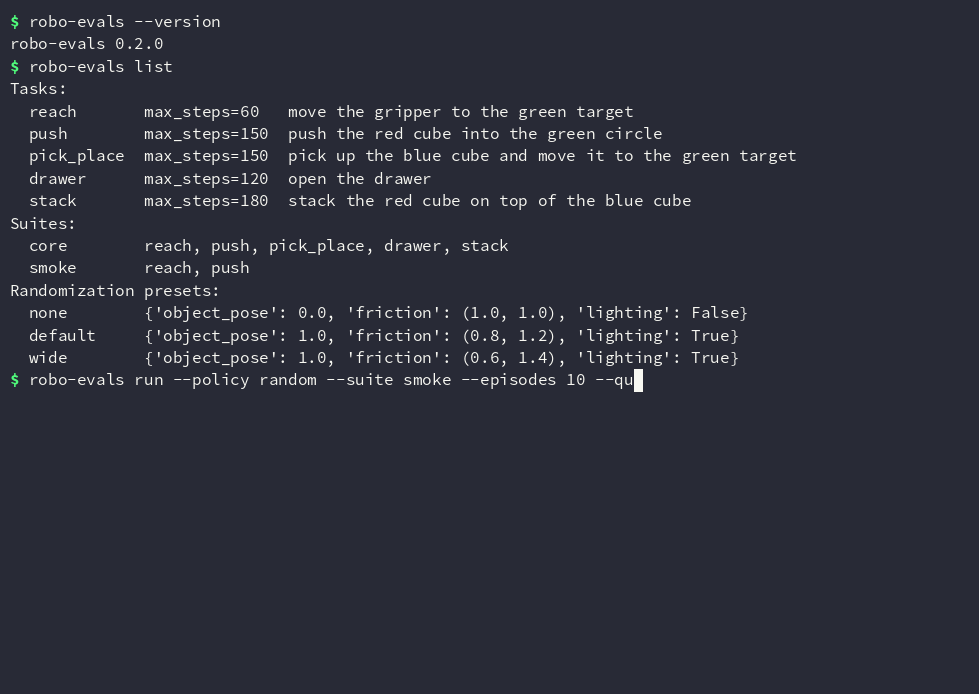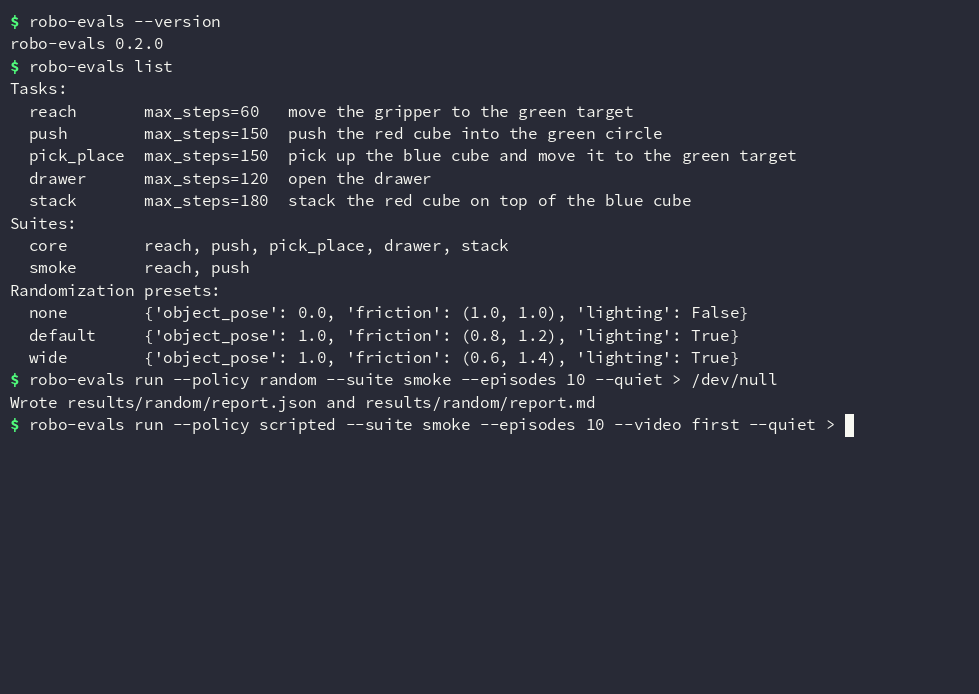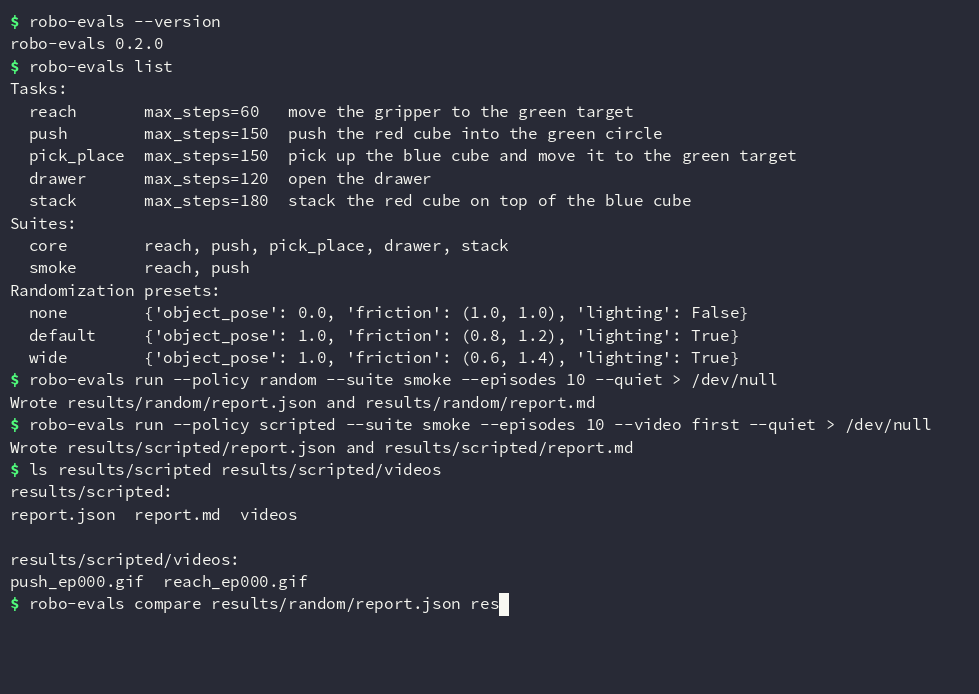
The recording above is a real session with the released command line, not a mock-up.
Install
pip install "robo-evals[video]"
Run it
robo-evals run --policy scripted --suite core --episodes 20 --video first
robo-evals compare results/random/report.json results/scripted/report.json
Each run writes report.json, report.md, and videos under results/<policy>/.
Where to go next
- Architecture shows how a run flows from the command line to a report.
- Remote policy protocol explains how to evaluate a model in another process.
- FAQ answers the common questions about seeds, intervals, and rendering.
- Decisions records why the harness works the way it does.